Woit · §2.1 Some representation theory
英文原文
Woit §2.1 identifies a Lie group as a differentiable manifold but gives no chart/atlas definition here. The complete registered definition is Szekeres §15.1.
原文相关讨论摘录
We are mainly interested in the case of a Lie group, where is a differentiable manifold of some dimension. In such a case we will restrict attention to representations given by differentiable maps . As a space, is the space of all by complex matrices, with the locus of non-invertible (zero determinant) elements removed. Choosing local coordinates on will be given by real functions on and the condition that is a differentiable manifold means that the derivative of is consistently defined. Our focus will be not on the general case, but on the study of certain specific Lie groups and representations which are of central interest in quantum mechanics. For these representations one will be able to readily see that the maps are differentiable.
来源与版本
正文:英文原文
来源版本:2025-10-20
原文位置:§2.1;PDF 页 31;印刷页 14
处理记录:PDF 文字层提取;MinerU OCR;AI 辅助转录对照
核对状态:AI 辅助转录核对,未作人工审阅或数学审稿
来源 PDF SHA-256:5a1941b2443b54d5db3d055f1e5ba390429b7a728475258017aaac87ee85a837
中文译文
Woit §2.1 将李群称为可微流形,但这里没有给出图册/坐标定义;完整来源指向 Szekeres §15.1。
译文摘录
我们主要感兴趣的是为李群的情形,此时是某个维数的可微流形。在这种情况下,我们将只关注由可微映射给出的表示。作为空间,是所有乘复矩阵构成的空间,并去掉不可逆(行列式为零)元素构成的轨迹。在上选取局部坐标将由上的个实函数给出,而是可微流形这一条件意味着的导数被一致地定义。我们的重点不是一般情形,而是研究量子力学中具有核心意义的某些特定李群和表示。对于这些表示,人们将能够容易地看出映射是可微的。
来源与版本
正文:中文译文
来源版本:2025-10-20
原文位置:§2.1;PDF 页 31;印刷页 14
处理记录:machine-translation/deepseek-v4.1-flash
核对状态:机器译稿 · 待校对
Szekeres · §15.1 可微流形
英文原文
Szekeres defines a differentiable manifold as a topological n-manifold equipped with a maximal C∞-compatible atlas; its smoothness convention is explicitly C∞.
原文定义摘录
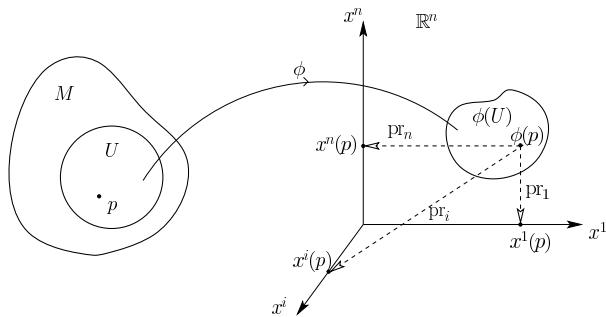
A locally Euclidean space or topological manifold of dimension is a Hausdorff topological space in which every point has a neighbourhood homeomorphic to an open subset of . If is any point of then a (coordinate) chart at is a pair where is an open subset of , called the domain ofthe chart and is a homeomorphism between and its image . The image is an open subset of , given the relative topology in . It is also common to call a coordinate neighbourhood of and a coordinate map. The functions , where are the standard projection maps, are known as the coordinate functions determined by this chart, and the real numbers are called the coordinates of in this chart (see Fig. 15.1). Sometimes, when we wish to emphasize the symbols to be used fo the coordinate functions, we denote the chart by , or simply . Occasionally the term coordinate system at is used for a chart whose domain covers . The use of superscripts rather than subscripts for coordinate functions is not universal, but its advantages will become apparent as the tensor formalism on manifolds is developed.
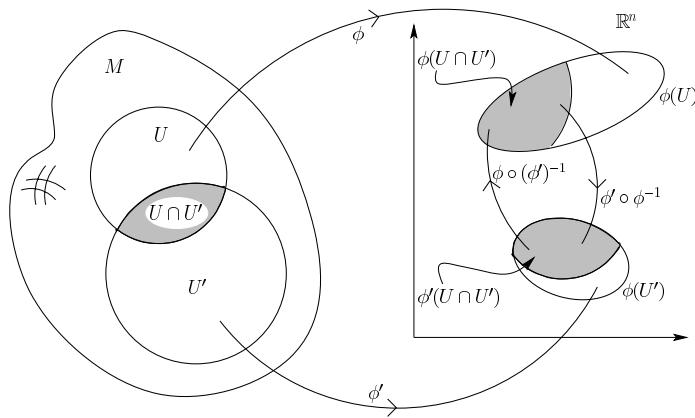
For any pair ofcoordinate charts ) and such that , define the transition functions
Figure 15.1 Chart at a point
Figure 15.2 Transition functions on compatible chartwhich are depicted in Fig. 15.2. The transition functions are often written
which is an abbreviated form of the awkward, but technically correct,
The two charts are said to be -compatible where is a non-negative integer or if al the functions in Eq. (15.1) are . For convenience we will generally assume that the charts are
An atlas on is a family of charts such that the coordinate neighbourhoods cover , and any pair of charts from the family are -compatible. If and are two atlases on then so is their union
Prove this statement. [Hint: A differentiable function of a differentiable function is always differentiable.]
Any atlas may thus be extended to a maximal atlas by adding to it all charts that are -compatible with the charts of . This maximal atlas is called a differentiable structure on . A pair , where , is an -dimensional topological manifold and is a differentiable structure on , is called a differentiable manifold; it is usually just denoted .
来源与版本
正文:英文原文
来源版本:source-snapshot-bc3404156f6e
原文位置:§15.1;PDF 页 2、3;印刷页 411、412
处理记录:既有整理 OCR 稿
核对状态:尚未完成转录核对
中文译文
Szekeres 将可微流形定义为带有极大 C∞ 相容图册的拓扑 n 维流形;这里的光滑性约定明确为 C∞。
译文摘录
局部欧几里得空间或 拓扑流形(topological manifold) 的维数为 ,是一个豪斯多夫拓扑空间 ,其中每一点 都有一个邻域同胚于 的开子集。如果 是 的任意一点,那么在 处的一个 坐标卡(coordinate chart) 是一对 ,其中 是 的开子集,称为该坐标卡的定义域,而 是 与其像 之间的同胚。像 是 的开子集,赋予 中的相对拓扑。也常将 称为 的 坐标邻域(coordinate neighbourhood),将 称为 坐标映射(coordinate map)。函数 ,其中 是标准投影映射,称为由该坐标卡确定的 坐标函数(coordinate function),而实数 称为 在该坐标卡中的坐标(见图 15.1)。有时,当我们希望强调用于坐标函数的符号时,我们将坐标卡记作 ,或简记为 。偶尔,术语“在 处的坐标系”被用于定义域 覆盖 的坐标卡。坐标函数使用上标而非下标并非普遍做法,但随着流形上张量形式体系的发展,其优点将变得明显。
对于任意一对坐标卡 与 ,若 ,则定义 过渡函数(transition function)
图 15.1 在点 处的坐标卡
图 15.2 相容坐标卡上的过渡函数它们如图15.2所示。过渡函数常写作
它是这一笨拙但在技术上正确的表述的缩写形式,
若方程 (15.1) 中的所有函数都是 ,则称这两张图卡是 -相容的,其中 为非负整数或 。为方便起见,我们通常假定这些图卡是
上的 图册(atlas) 是一族图卡 ,使得坐标邻域 覆盖 ,且该族中任意一对图卡都是 相容的。若 与 是 上的两个图册,则它们的并集 也是。
证明该命题。[提示:可微函数的可微函数总是可微的。]
因此,任何图册 都可以通过向其中添加所有与 的图卡 相容的图卡,从而扩展为一个 极大图册(maximal atlas)。这个极大图册称为 上的一个 可微结构(differentiable structure)。若 是一个 维拓扑流形,且 是 上的一个可微结构,则称有序对 为一个 可微流形(differentiable manifold);通常就简记为 。
来源与版本
正文:中文译文
来源版本:source-snapshot-bc3404156f6e
原文位置:§15.1;PDF 页 2、3;印刷页 411、412
处理记录:整理译文;机器参与见编校记录
核对状态:译文尚未审核